SenseLabRobo

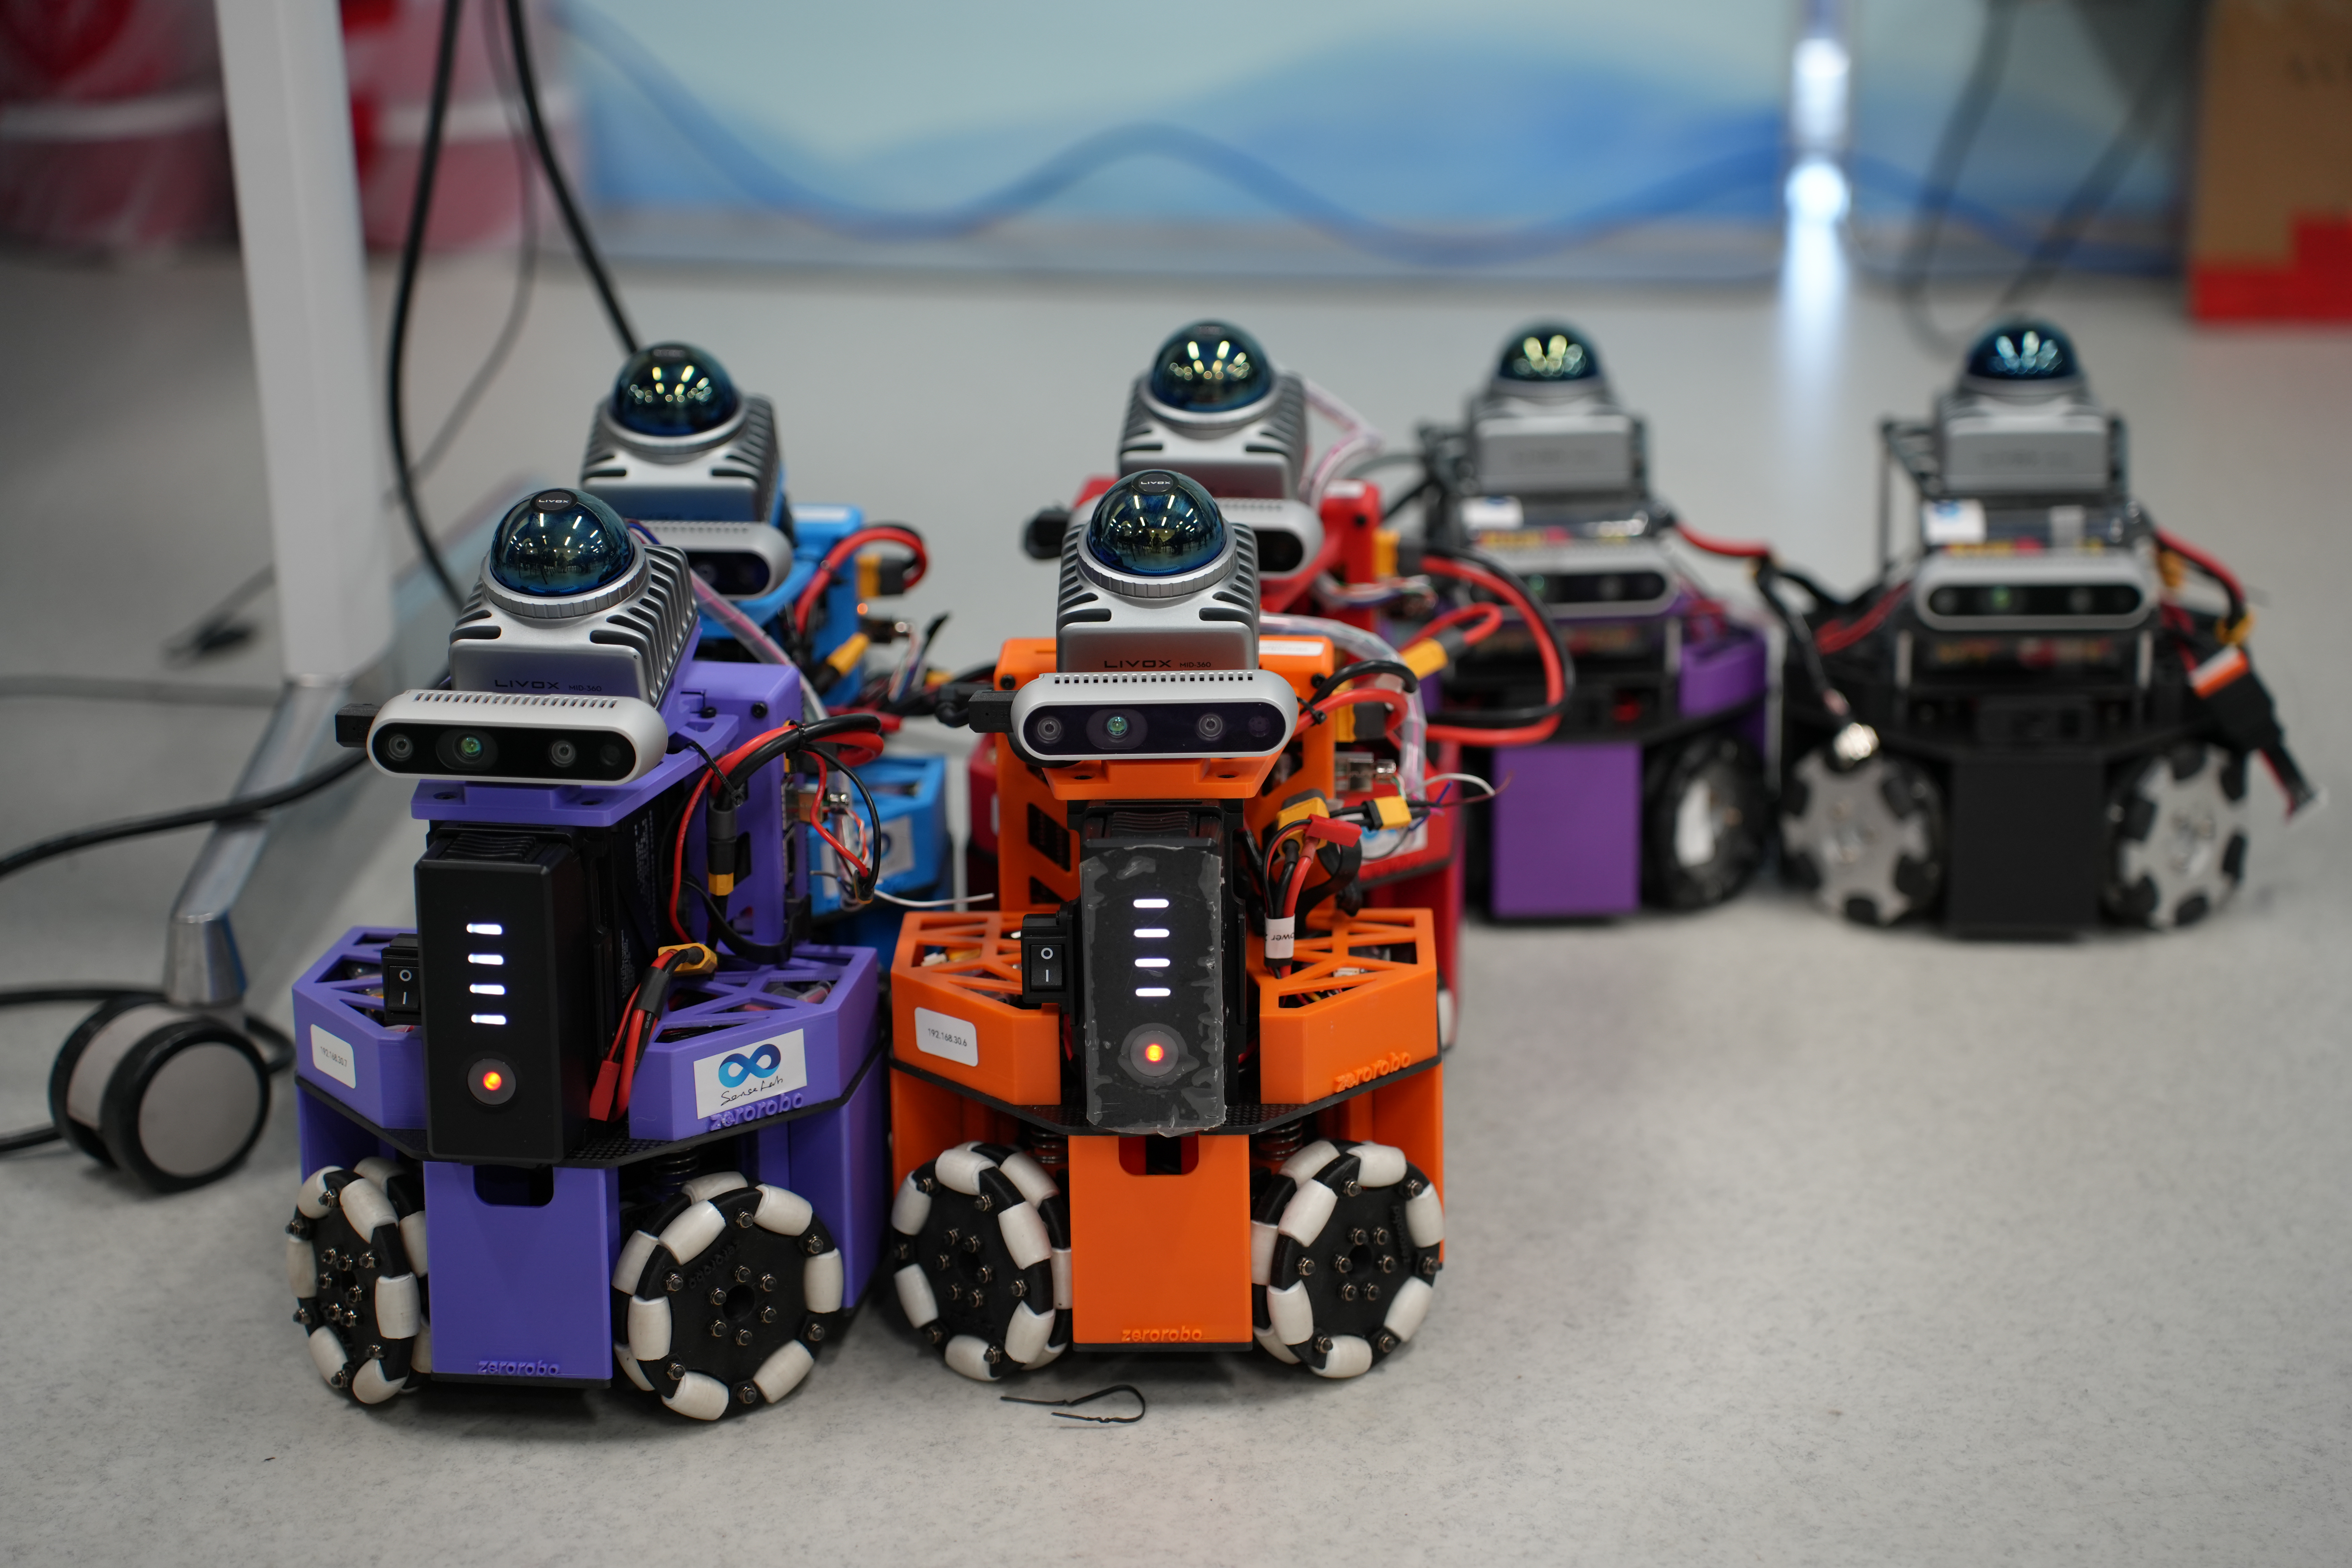
SenseLabRobo mobile robot fleet
GitHub

Our Mission

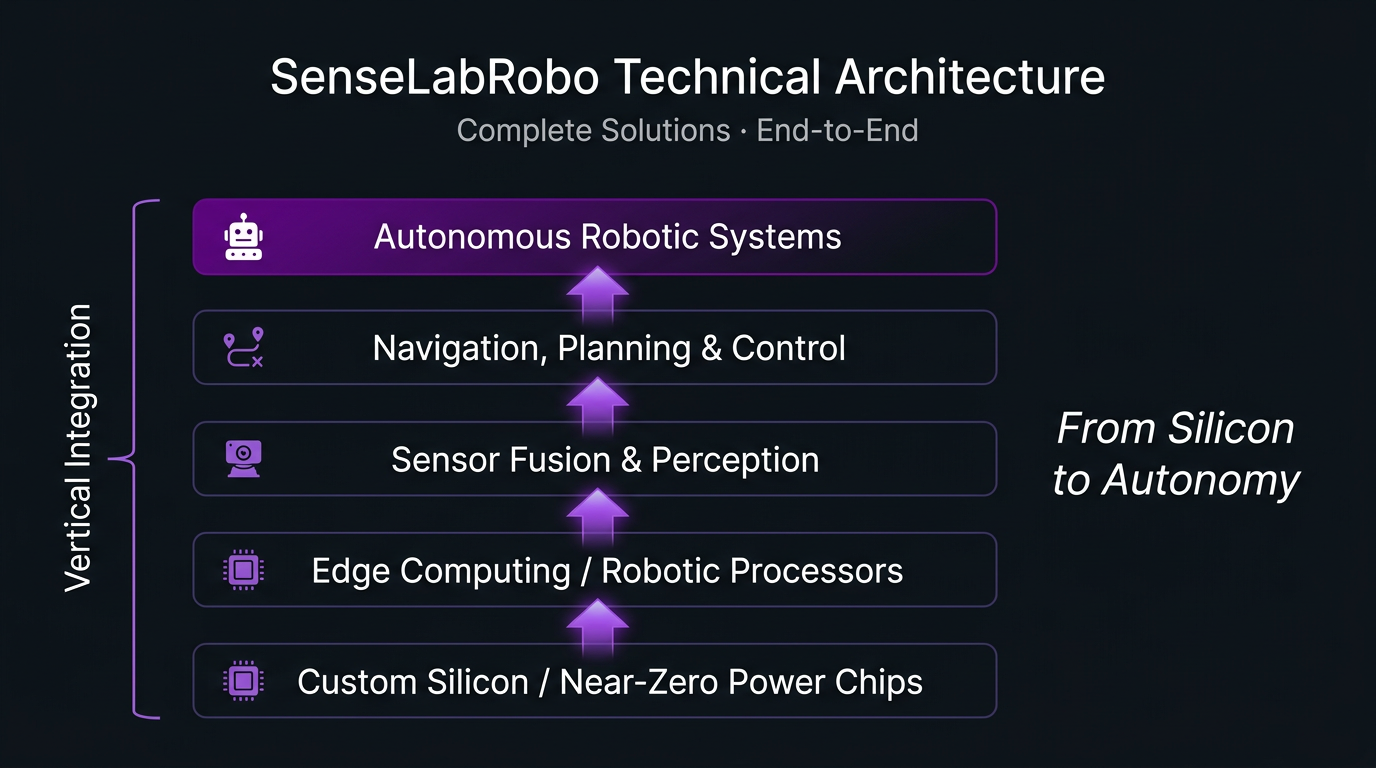
SenseLabRobo was founded with a clear conviction: the future of robotics lies in the vertical integration of processors and systems. We don't chase breadth — we pursue depth. By building complete technical solutions from custom robotic chips to full-stack intelligent systems, we solve specific, real-world problems end-to-end. This is our Promethean logic — forging every link in the chain, from silicon to autonomy.

SenseLabRobo Technical Architecture
🔬

Robotic Processor Design

Designing near-zero power, high-efficiency chips purpose-built for robotic perception and control at the edge.

⚡

Full-Stack System Integration

Vertically integrating custom silicon, sensor fusion, and intelligent algorithms into complete robotic platforms.

🤖

Edge Embodied Intelligence

Deploying autonomous perception, navigation, and decision-making directly on resource-constrained robotic hardware.


The Team

Driven by curiosity, united by code. We are a diverse group of researchers.

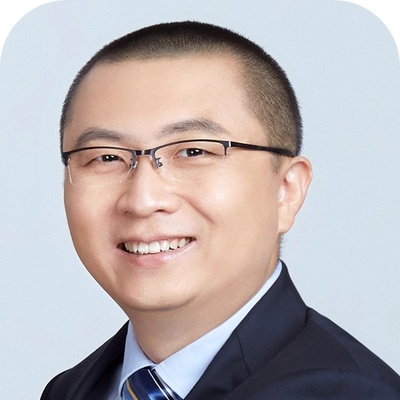
Dr. Fei Qiao

Dr. Fei Qiao

Principal Investigator / Associate Professor
Department of Electronic Engineering, Tsinghua University
Research Lead: Edge Embodied Intelligence, Flexible Wearable Device, Near-zero Power Chips, High Energy Efficiency Intelligence System
✉️ Email  |  🌐 Faculty Homepage
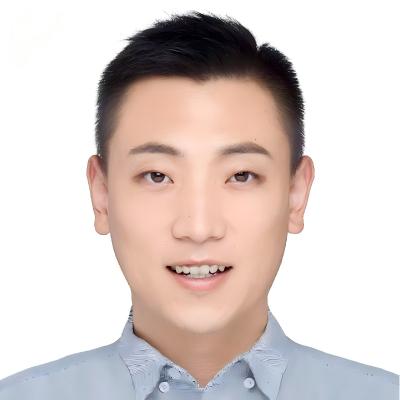
Dr. Rong Zhao

Dr. Rong Zhao

Lecturer / Former Postdoctoral Researcher
North University of China (Lecturer) & Tsinghua University (Postdoctoral appointment completed)
Research Focus: Robot Navigation
✉️ Email
Dr. Qian Zhang

Dr. Qian Zhang

Team Leader / Postdoctoral Researcher
Ph.D. graduate, Tsinghua SIGS, Tsinghua University
Research Focus: Perception & SLAM
Researchers
Haohua Que
Haohua Que
Ph.D. Student
College of Engineering, University of Georgia
Focus: Robotic Control
Haojia Gao
Haojia Gao
Master Student
Tsinghua SIGS, Tsinghua University
Focus: Embodied Intelligence
Mingkai Liu
Mingkai Liu
Master Student
School of Software & Microelectronics, Peking University
Focus: 3D Reconstruction & Localization
Yunchao Mo
Yunchao Mo
Master Student
College of CS & AI, Southwest Minzu University
Focus: Reinforcement Learning
Hui Geng
Hui Geng
Master Student
School of Comm. & Info. Eng., Chongqing Univ. of Posts & Telecom.
Focus: Multi-Robot Exploration
Chengkui Wang
Chengkui Wang
Master Student
Computer Science & Technology, Tiangong University
Focus: 3D Reconstruction & Autonomous Driving Simulation
Hongyi Xu
Hongyi Xu
Master Student
Central Saint Martins, University of the Arts London
Focus: Robotic Structural Design & Industrial Design
Chaojie Chen
Chaojie Chen
Master Student
School of Automation, Guangdong University of Technology
Focus: Embedded Software & Hardware
Chunhong Yuan
Chunhong Yuan
Master Student
Faculty of Control Systems and Robotics, ITMO University
St. Petersburg, 197101, Russia
Focus: Machine Learning Applications in Robotics, Intelligent Control Systems, and Interdisciplinary AI
Yifan Zhu
Yifan Zhu
Undergraduate
Xiuzhong College, Tsinghua University
Yuyang Song
Yuyang Song
Undergraduate
Information & Electronics, Beijing Institute of Technology
Focus: Robotics
Jiajun Sun
Jiajun Sun
Undergraduate
School of Mech. & Elec. Eng., Shenzhen University
Focus: Robotics
Shanxu Zhao
Shanxu Zhao
Undergraduate
Dept. of Electronic Engineering, Tsinghua University
Yannong Wen
Yannong Wen
Undergraduate (Senior)
Fan Gongxiu Honors College, Beijing University of Technology
Hoi Ian Au
Hoi Ian Au
Undergraduate
Dept. of Electronic Engineering, Tsinghua University
Focus: Robotics & Agentic Systems
Jiayue Xie
Jiayue Xie
Undergraduate
Electronic Information, Beijing Forestry University
Yong Yu
Yong Yu
Undergraduate
Mathematics & Applied Mathematics, Central South University

Selected Publications

Our research has been published in top-tier robotics and AI venues.

Under Review
SenseSwarm: Swarm Exploration via Neural Structure Estimation with Shared World-Anticipation for Rapid Mapping ICRA Under Review
ASPC: Adaptive Sequence-Parallel Collaborative Inference for Resource-Constrained Multi-Robot Exploration ICRA Under Review
HERO-Explore: Consequence-Aware Collaboration for Heterogeneous Robot Exploration ICRA Under Review
RC-MRE: Benchmarking Resource Robustness in Multi-Robot Exploration ICRA Under Review
DAC-MACE: Dynamic Attention-driven Context Mixture-of-Experts for Large-Scale Visual Relocalization Under Review
Zero-Shot Semantics-enhanced Autonomous Exploration in Complex Unknown Environments Under Review
Kinematic-Aware Improved Hippo Optimization with Laplacian Ironing for Swarm-based Path Planning in Cluttered Environments Under Review
2025 / 2026
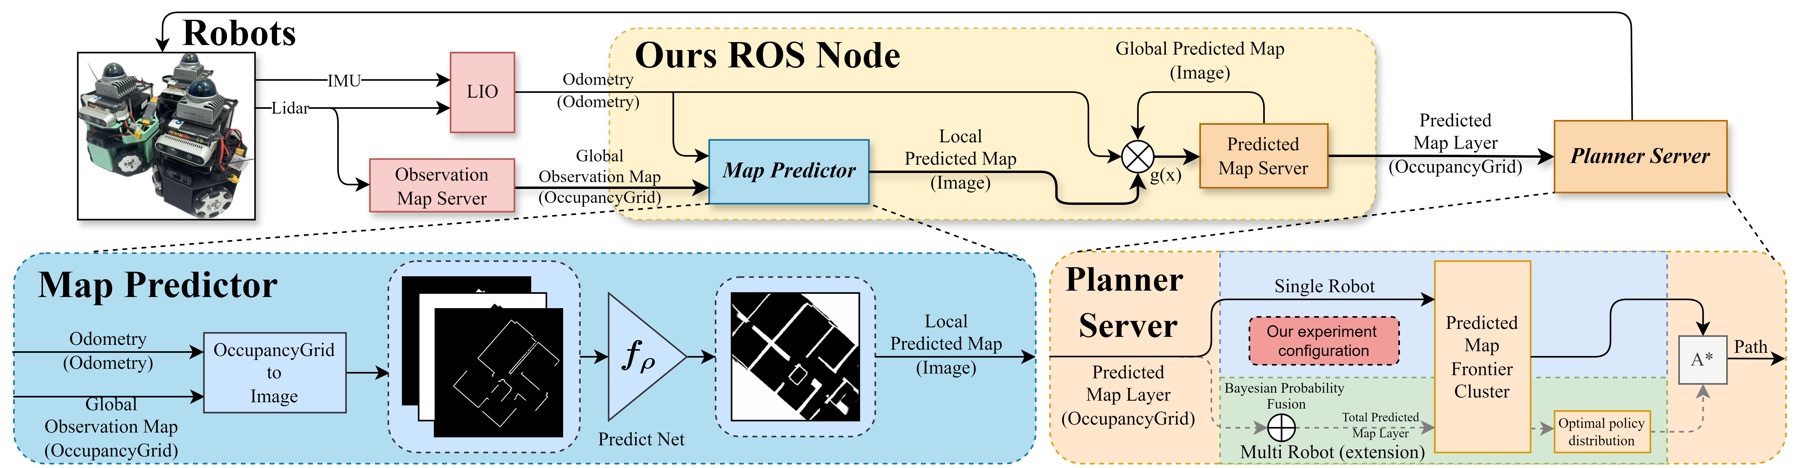
SenseExpo: Spatial Exploration and Navigation via Scene Estimation from Expeditious Predictive Updates
IROS 2026 (Accepted)
SenseExpo robot exploration and map prediction pipeline
System overview from the public SenseExpo preprint.
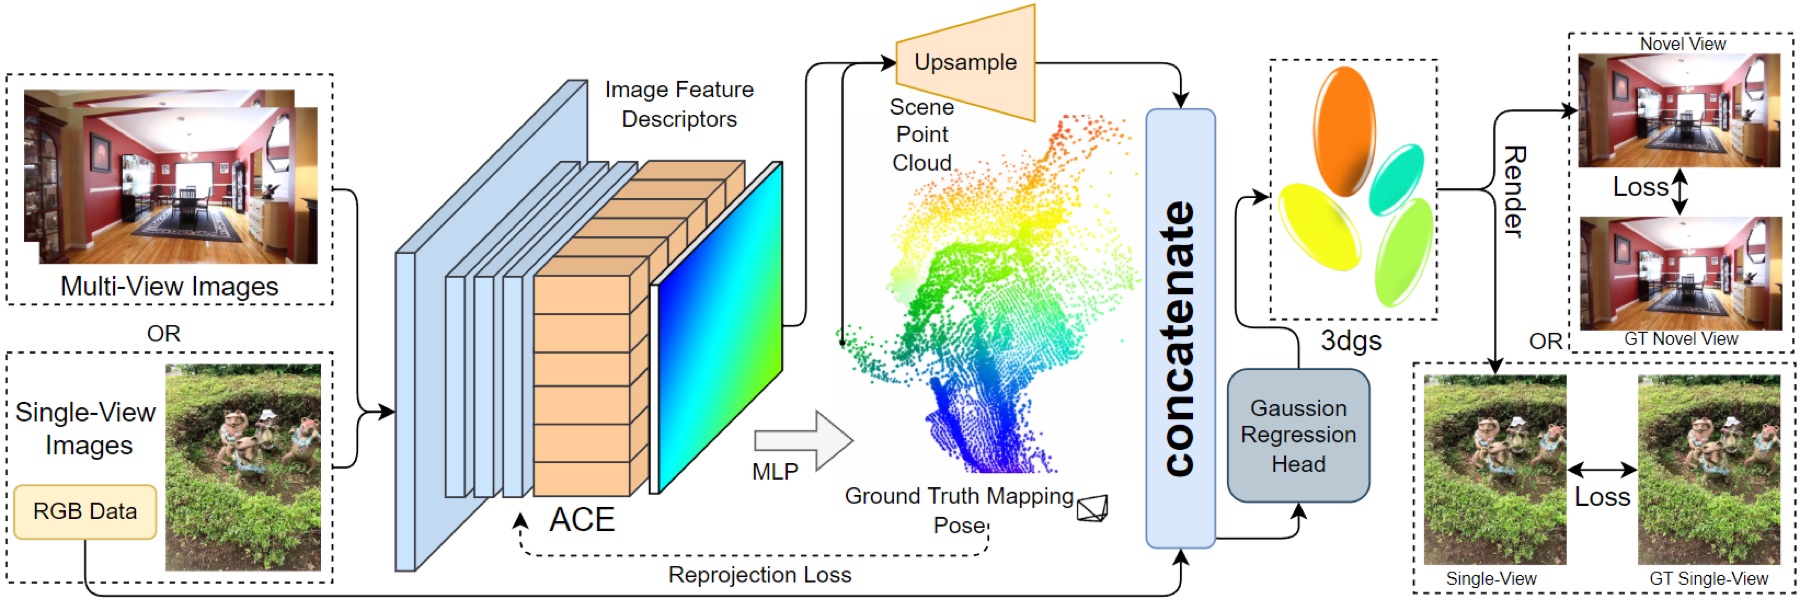
ACESplat: Accelerated 3D Gaussian Scene Regression via RGB and Poses Only
IROS 2026 (Accepted)
ACESplat scene coordinate regression and 3D Gaussian reconstruction pipeline
Pipeline overview from the public paper.
ST-GRL: Spatiotemporal Cognitive Graph Reinforcement Learning for Scalable Multi-Robot Collaborative Exploration
IROS 2026 (Accepted)
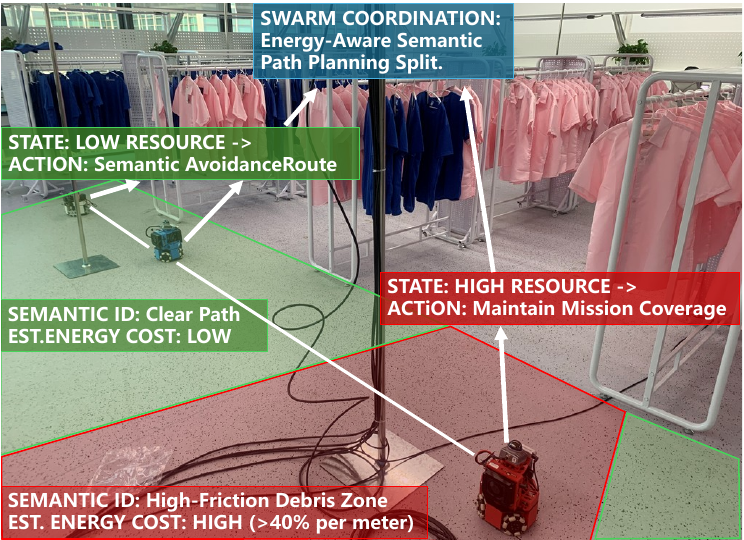
ST-GRL energy-aware semantic path planning with two robots
Motivating example from the paper (Fig. 1).
M. Liu, D. Fan, H. Que, H. Gao, X. Liu, S. Peng, M. Lin, S. Gu, R. Ye, W. Qiu, H. Yao, R. Zhang, X. Huang
ICRA 2026 (Accepted) • arXiv:2510.14251
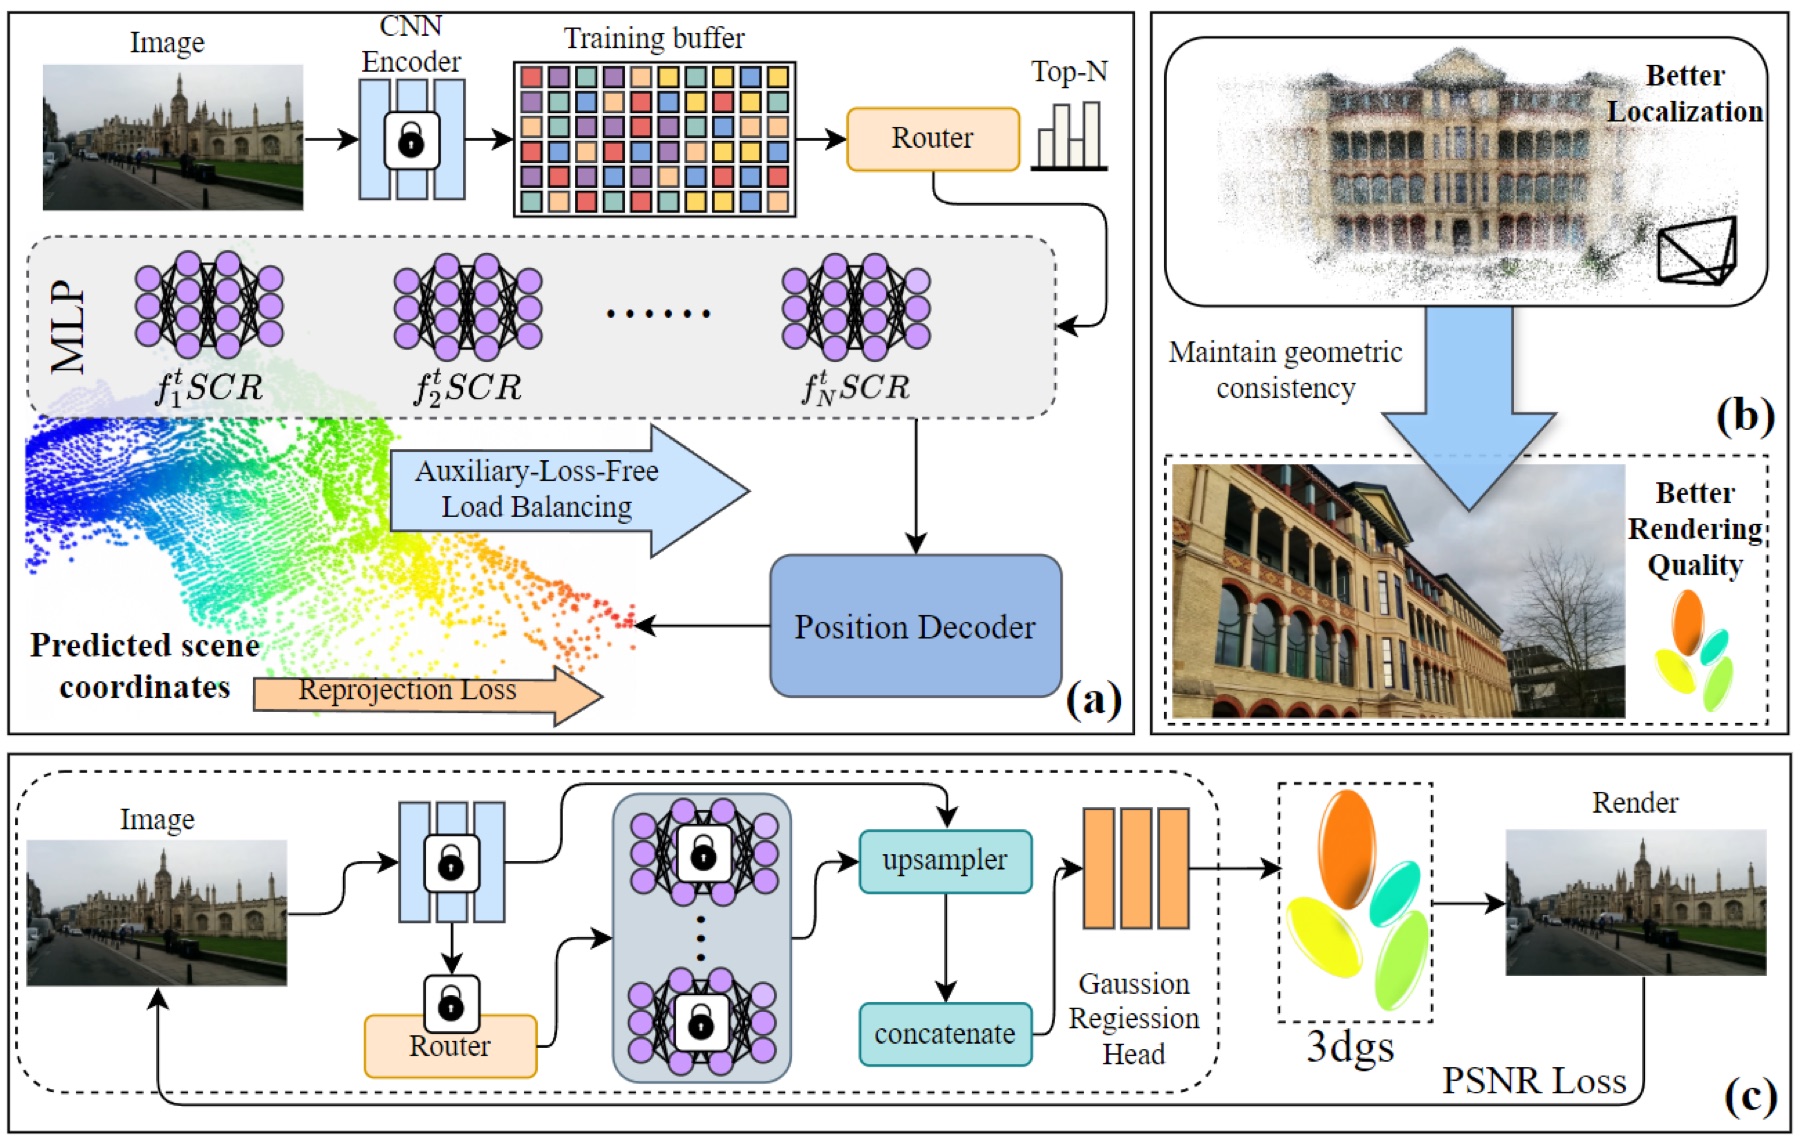
MACE localization and rendering pipeline
Pipeline overview from the public paper.
H. Que, M. Liu, J. Xie, H. Gao, J. Sun, H. Xu, H. Yao, F. Qiao
IJCNN 2026 (Accepted) • WCCI 2026
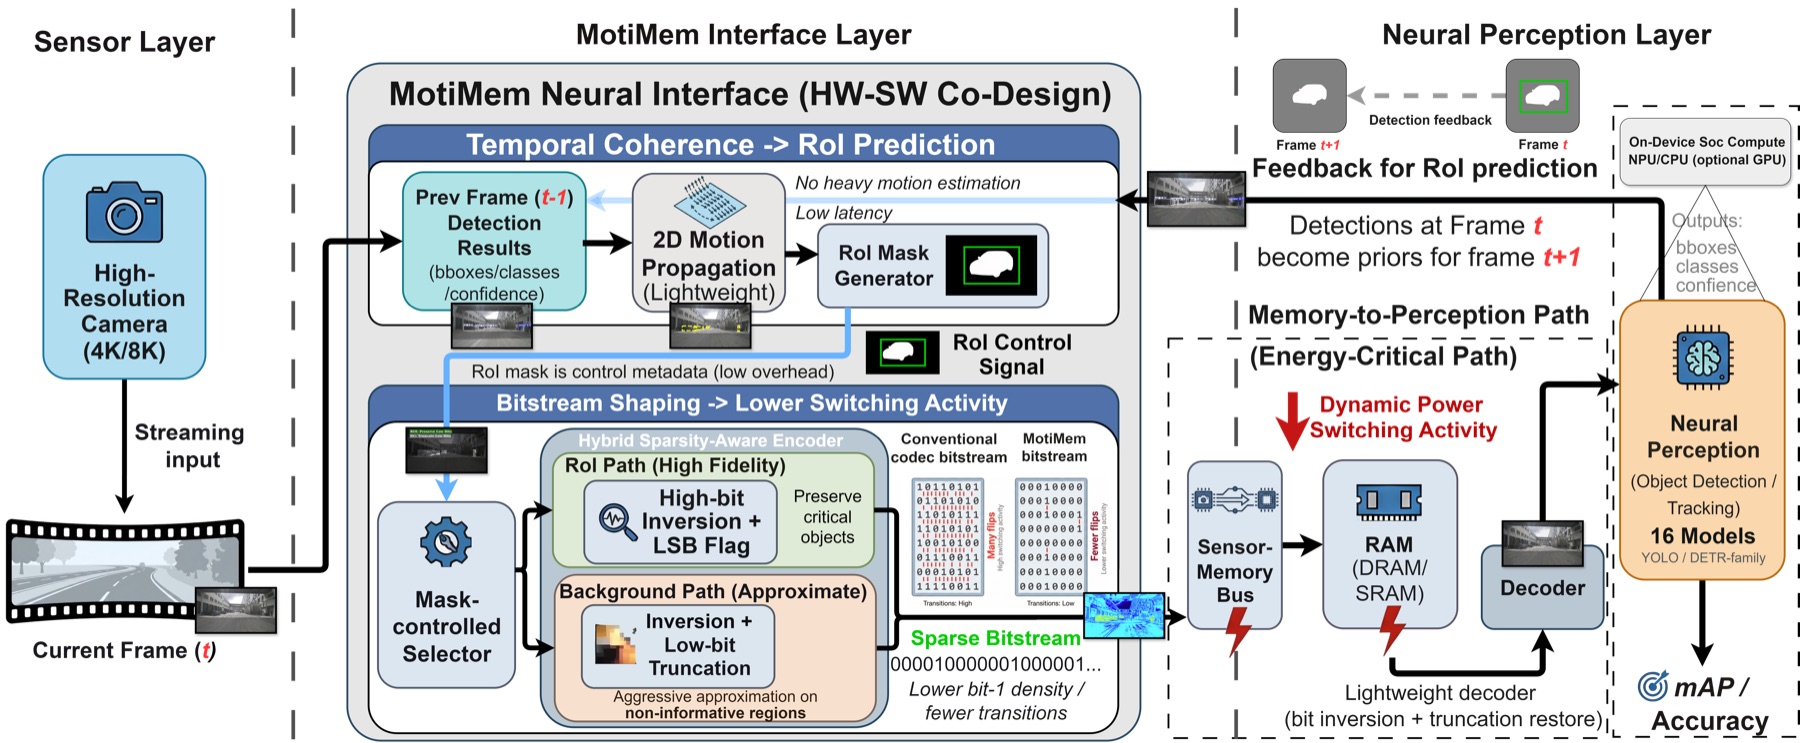
MotiMem motion-aware memory interface for neural perception
System diagram from the public paper.
R. Li, Y. Mo, R. Zhao, H. Gao, H. Que, L. Mu
IROS 2025 • pp. 1847-1854 • IEEE
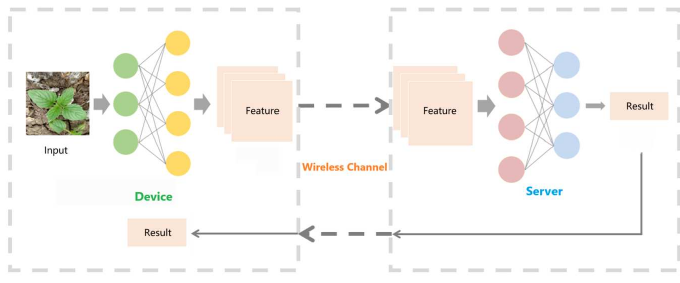
Device-to-server wireless collaborative inference pipeline
Wireless collaborative inference concept from the paper (Fig. 1).
H. Gao, H. Que, K. Li, W. Shan, M. Liu, R. Zhao, L. Mu, X. Yang, Q. Wei, F. Qiao
IJCNN 2025 • arXiv:2504.04061
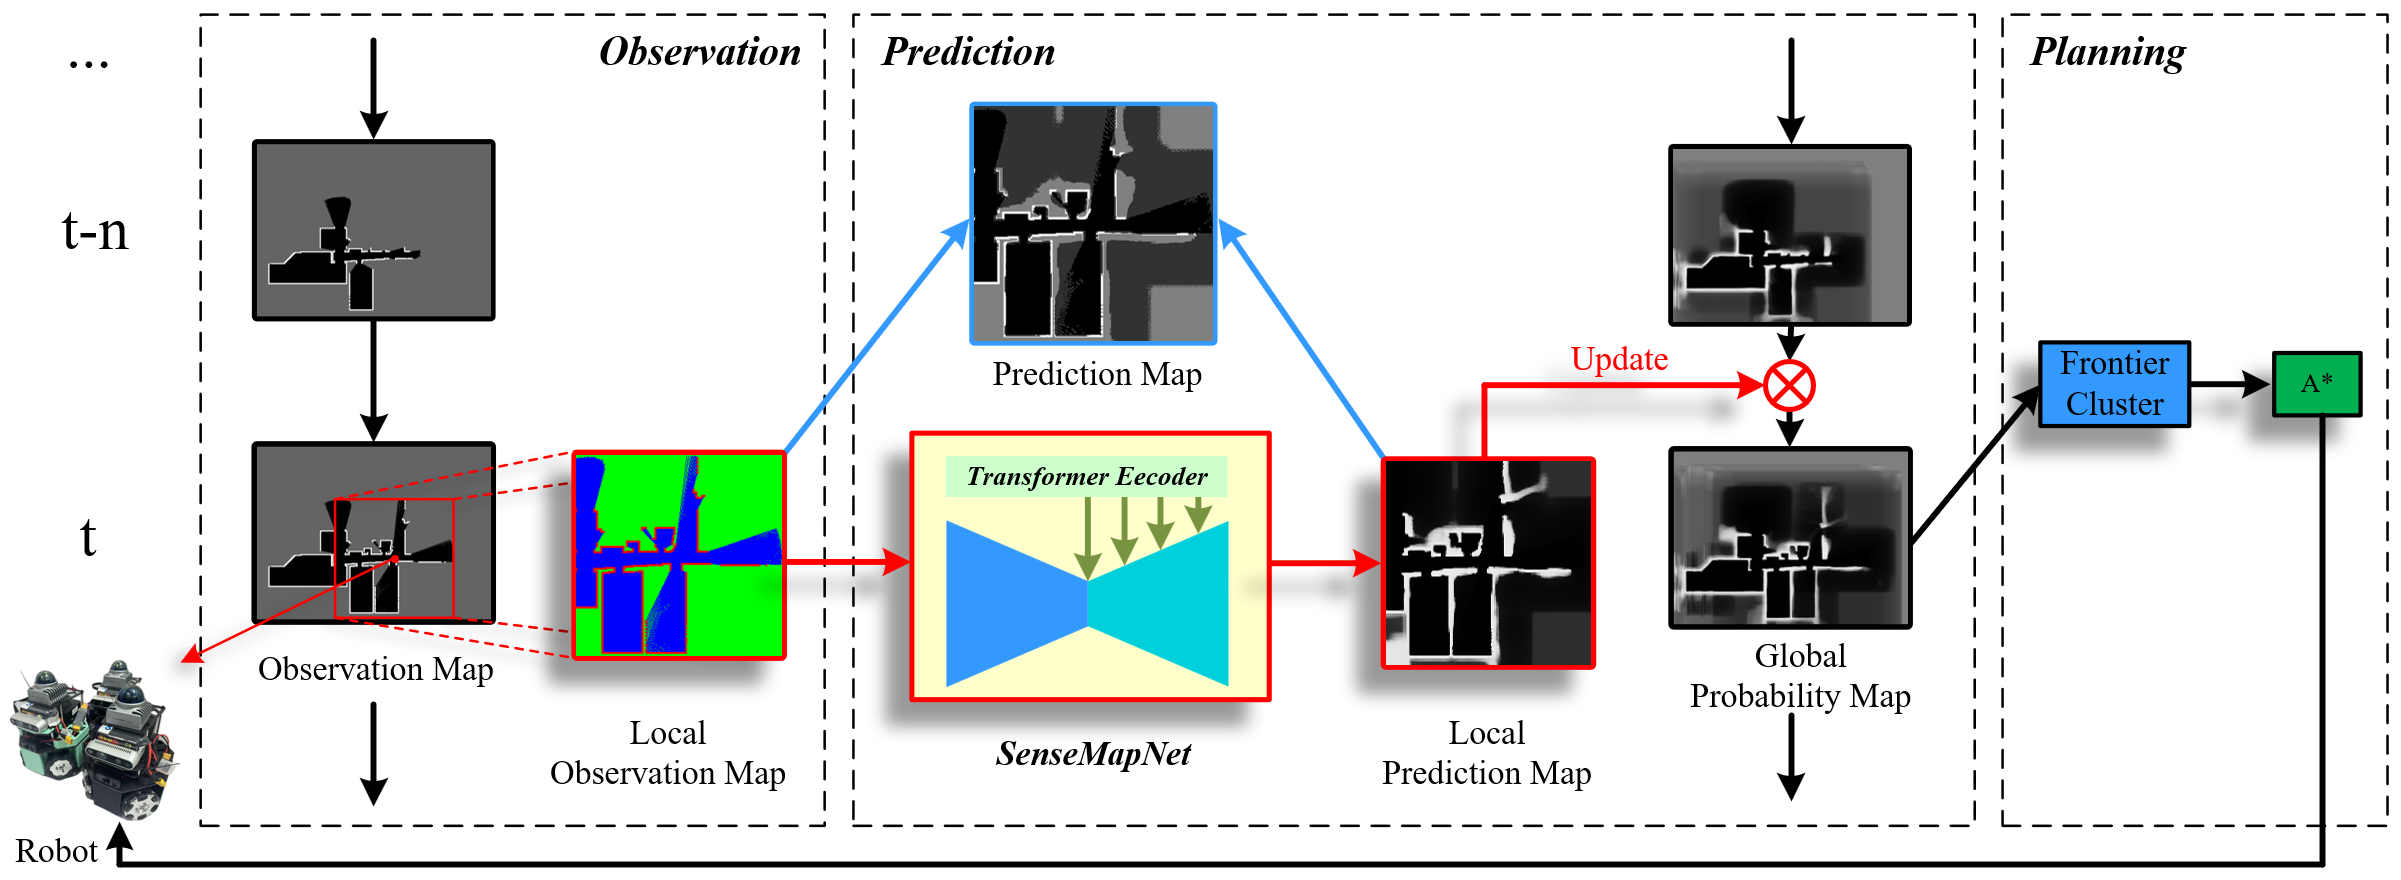
SenseMap observation, prediction, and planning pipeline
Pipeline overview from the public paper.
H. Que, H. Gao, M. Liu, H. Au, H. Yao, F. Qiao
IROS 2025 Workshop on Edge AI for Robotics
2022
Q. Zhang, R. Quan, S. Qimuge, P. Xia, J. Wang, X. Zan, F. Wang, C. Chen, Q. Wei, H. Zhao, X. Liu, F. Qiao
IROS 2022 • pp. 2556-2563 • IEEE
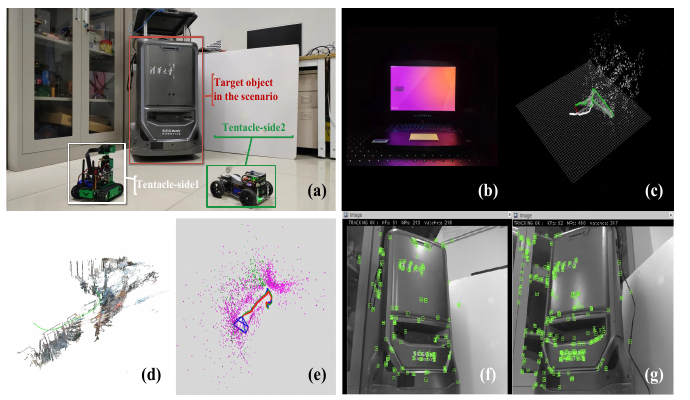
OCTOANTS multi-robot mapping system and results
Multi-robot collaboration and mapping results from the paper (Fig. 1).
Q. Zhang, R. Quan, S. Qimuge, R. Wei, X. Zan, F. Wang, C. Chen, Q. Wei, X. Liu, F. Qiao
CASE 2022 • pp. 842-848 • IEEE
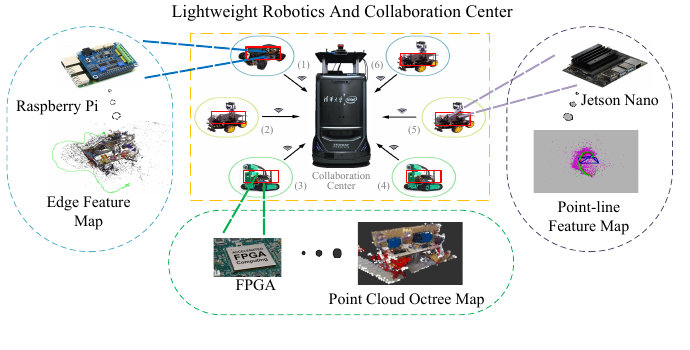
Heterogeneous multi-robot social system architecture
Multi-robot system concept map from the paper (Fig. 1).
2021
D. Li, J. Miao, X. Shi, Y. Tian, Q. Long, T. Cai, P. Guo, H. Yu, W. Yang, H. Yue, Q. Wei, F. Qiao
IROS 2021 • pp. 1331-1338 • IEEE
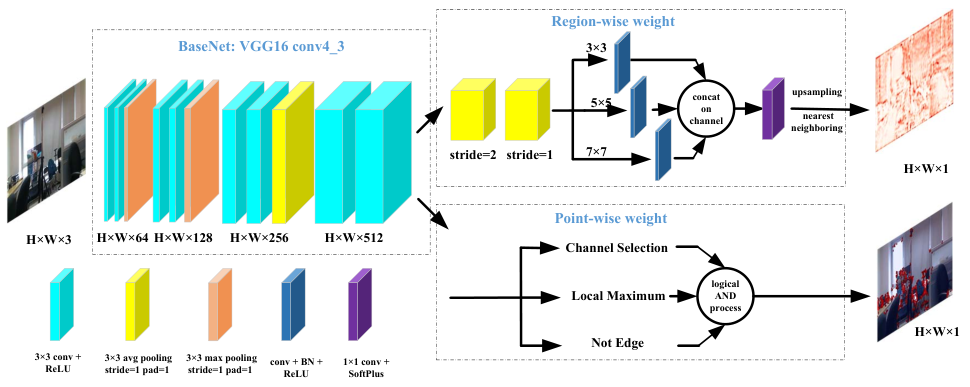
RaP-Net feature extraction network architecture
Network architecture from the public paper.
2020
D. Li, X. Shi, Q. Long, S. Liu, W. Yang, F. Wang, Q. Wei, F. Qiao
IROS 2020 • pp. 4958-4965 • IEEE
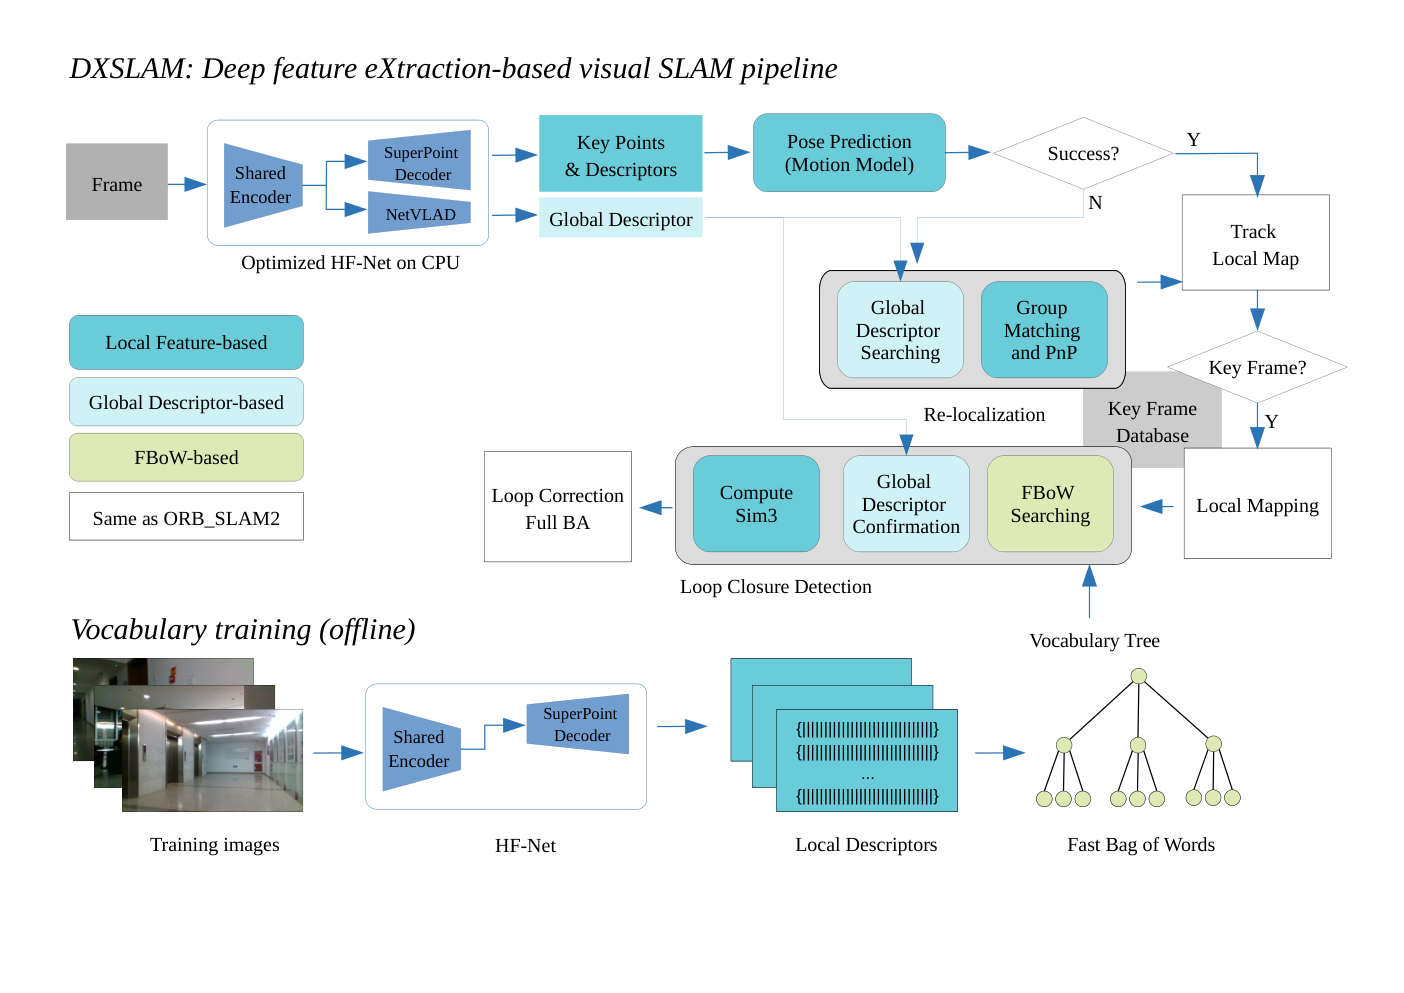
DXSLAM visual SLAM system framework
System framework from the public paper.
X. Shi, D. Li, P. Zhao, Q. Tian, Y. Tian, Q. Long, C. Zhu, J. Song, F. Qiao, L. Song, Y. Guo, Z. Wang, Y. Zhang, B. Qin, W. Yang, F. Wang, R.H.M. Chan, Q. She
ICRA 2020 • pp. 3139-3145 • IEEE
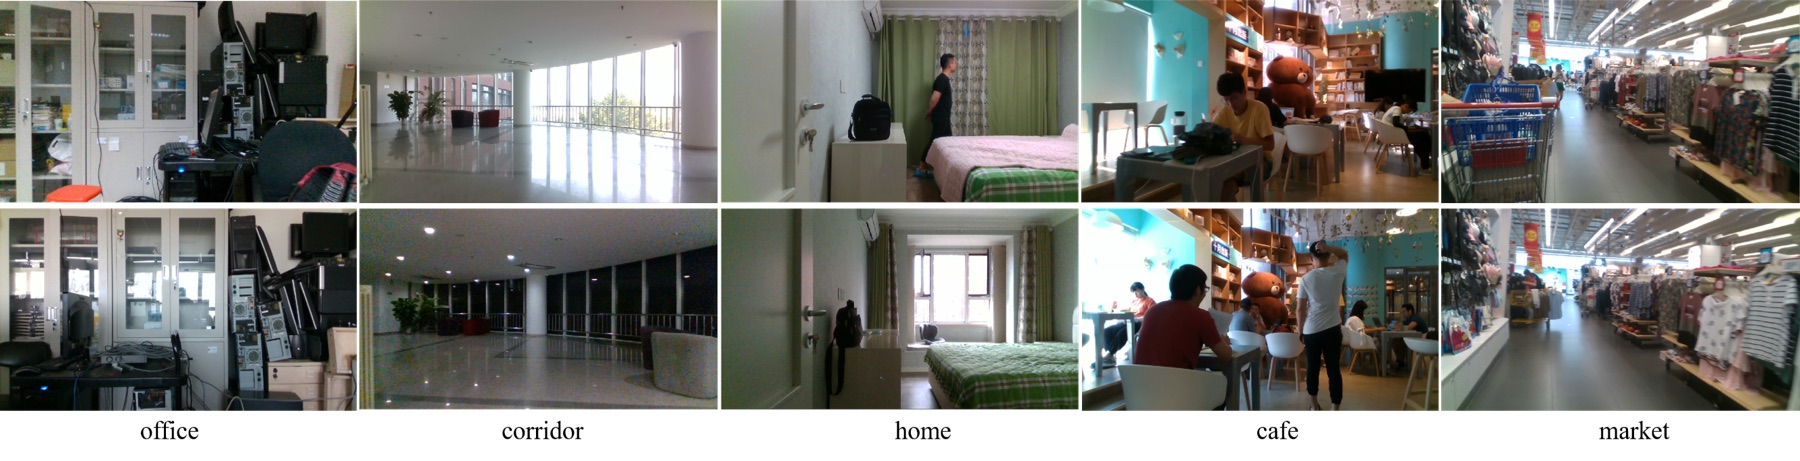
OpenLORIS scene changes across dataset sequences
Dataset examples from the public paper.
2019
C. Yu, Z. Liu, X. Liu, F. Qiao, Y. Wang, F. Xie, Q. Wei, Y. Yang
ROBIO 2019 • pp. 258-265 • IEEE
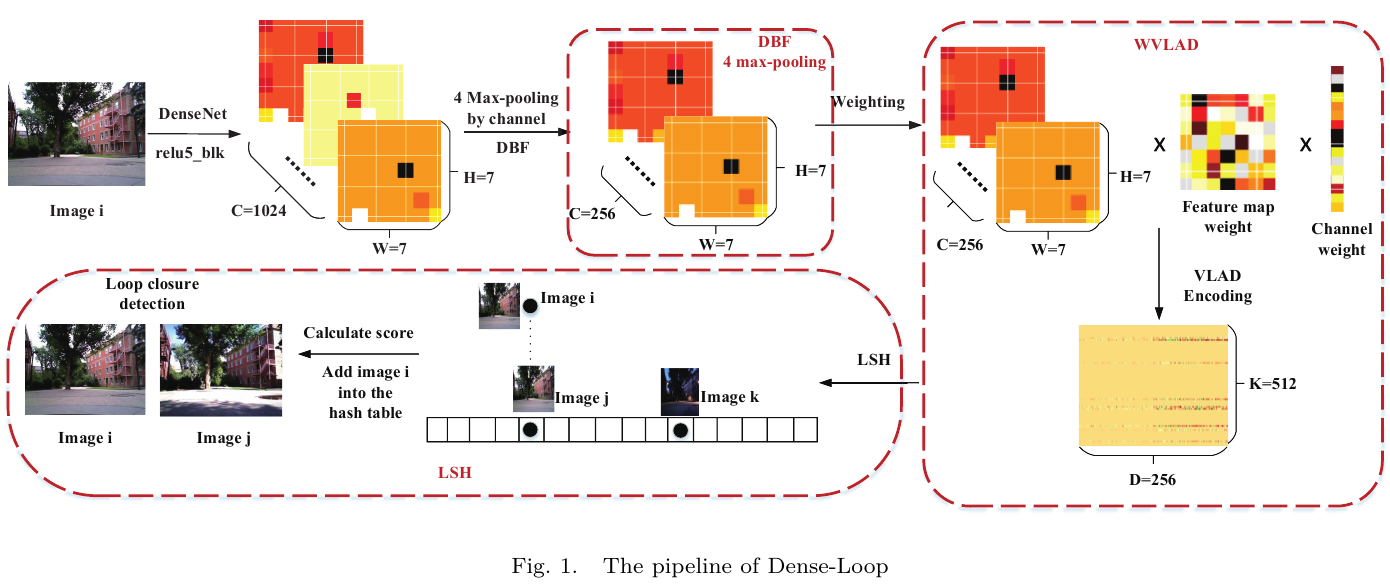
Dense-Loop visual SLAM loop closure pipeline
Dense-Loop pipeline from the paper (Fig. 1).
2018
C. Yu, Z. Liu, X. Liu, F. Xie, Y. Yang, Q. Wei, Q. Fei
IROS 2018 • pp. 1168-1174 • IEEE
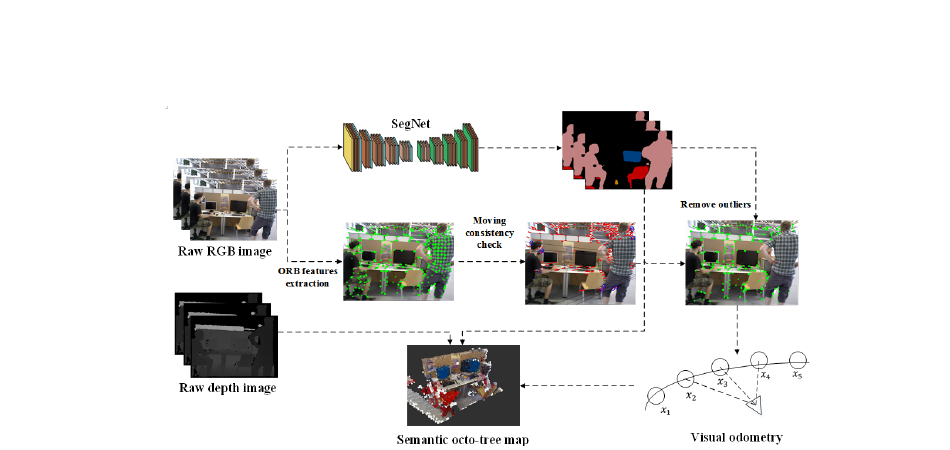
DS-SLAM semantic visual SLAM system overview
System overview from the public paper.
2017
C. Yu, X. Liu, F. Qiao, F. Xie
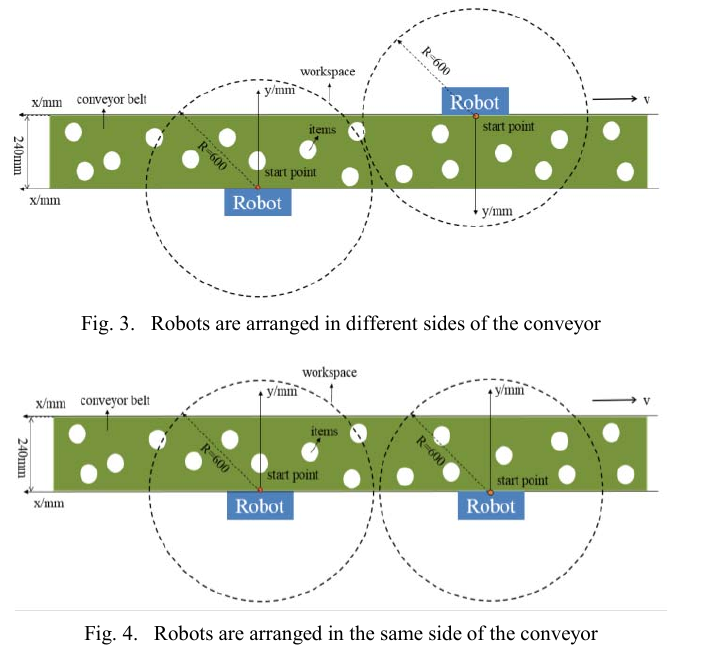
ROBIO 2017 • pp. 1743-1750 • IEEE
Two multi-robot conveyor-belt coordination layouts
Two robot arrangements from the paper (Figs. 3–4).

The SenseLab Tech Stack

We leverage cutting-edge tools to power our research.

Platforms & Middleware

Core Languages & Libraries

Hardware Focus

Affiliated Organizations

Sense Lab SenseLabRobo Infinity Robotics ZeroRobo D-Robotics MakeSens